Boston Dynamics, the Hyundai Motor Group's robot subsidiary, released footage of its Humanoid Robot Atlas fitted with wheels instead of feet.
A video posted on Boston Dynamics' YouTube channel on the 9th local time shows Atlas moving quickly as if on roller skates and changing direction freely. It also cleanly executed a 360-degree jumping spin, rotating once in the air like a figure skater before landing.
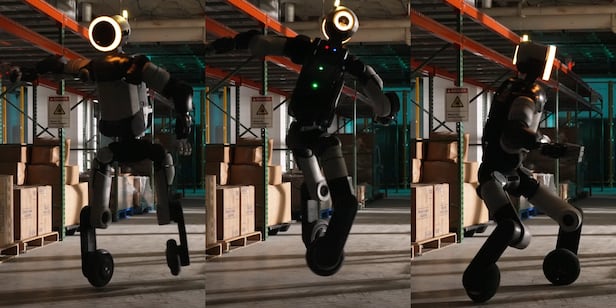
It balanced on one wheel while lifting the other leg and pushed itself up from the floor before accelerating forward. The robot adjusted full-body motion even as contact conditions with the ground changed.
The Atlas wheel type unveiled this time is for research, not for sale, and is meant to validate the performance of its drive units and whole-body control. The project also aims to ensure movement and reliability under extreme conditions.
"For a robot to drive on wheels, the motors must bear real loads during start, turn, and stop while consistently delivering high torque and speed," a Boston Dynamics official said. "It is a suitable setup to test the performance limits of the motors."
The core of the research is to reproduce in hardware, with stability, the motions learned in a virtual environment by modeling the real hardware with precision. To do that, the team precisely reflected motor behavior in the virtual environment and focused on narrowing the gap between simulation and real hardware through a sim-to-real process that applies motions learned in simulation to the physical robot.
After these steps, Atlas was able to successfully perform the humanlike 360-degree jumping spin on its first attempt, Boston Dynamics said.


